IEEE PerCom2023 (CORE A*)で本会議含む4件の発表
IEEE PerCom2023 (CORE A*)で本会議含む4件の発表
その他

国際会議 · 2023
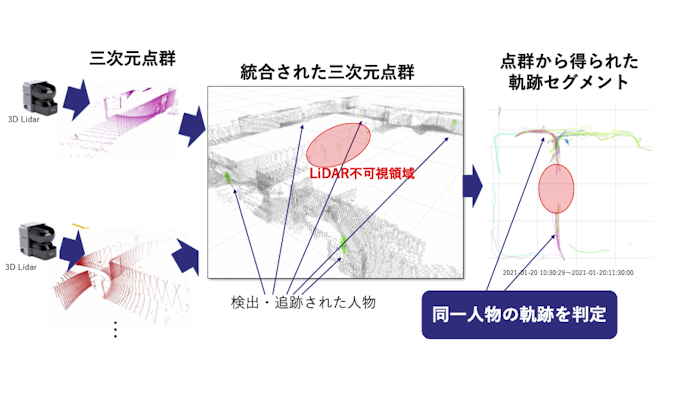
The growing demand for intelligent environments unleashes an extraordinary cycle of privacy-aware applications that makes individuals' life more comfortable and safe. Examples of these applications include pedestrian tracking systems in large areas. Although the ubiquity of camera-based systems, they are not a preferable solution due to the vulnerability of leaking the privacy of pedestrians. In this paper, we introduce a novel privacy-preserving system for pedestrian tracking in smart environments using multiple distributed LiDARs of non-overlapping views. The system is designed to leverage LiDAR devices to track pedestrians in partially covered areas due to practical constraints, e.g., occlusion or cost. Therefore, the system uses the point cloud captured by different LiDARs to extract discriminative features that are used to train a metric learning model for pedestrian matching purposes. To boost the system's robustness, we leverage a probabilistic approach to model and adapt the dynamic mobility patterns of individuals and thus connect their sub-trajectories. We deployed the system in a large-scale testbed with 70 colorless LiDARs and conducted three different experiments. The evaluation result at the entrance hall confirms the system's ability to accurately track the pedestrians with a 0.98 F-measure even with zero-covered areas. This result highlights the promise of the proposed system as the next generation of privacy-preserving tracking means in smart environments.
近年,公共施設や大型商業施設など様々な人々が行きかう空間における歩行者の人流解析の重要性が高まっている.人流データは,新型コロナウィルスの感染拡大に対する混雑状況のモニタリング,施設内の動線・広告配置の最適化,災害時の避難計画の設計に利活用されている.
山口研究室では,3次元測域センサ(LiDAR)を用いた歩行者のトラッキングシステム「ひとなび」を開発している.「ひとなび」は固定設置した複数LiDARからの3次元点群からの人物検出およびトラッキングを行うことで,一般的なカメラによる人物追跡で生じるプライバシー上の懸念を抑えて,LiDARの可視範囲内での歩行者移動軌跡のリアルタイム出力を可能にする.
しかし,センサコストや建造物の構造上の制約により,欠損なく関心領域全てをカバーするようなLiDAR設置は困難であることが多い.そこで本研究では,点群から得られた歩行者軌跡に対する人物再識別手法を提案する.
提案手法では
の2つの観点から,全軌跡ペアに対してそれが同一人物によるものである確率を求め,軌跡の再接続(マッチング)を実現する.また一定期間において特に高い確度でマッチングできた軌跡を抽出し,それらを以降の教師データとして利用することで,その空間固有のパターンを逐次的に学習し,マッチング精度の自動的な向上を可能にする.
発表論文: