国際会議 · 2025

No Labels, No Problem: Adaptive Disaster Prediction Using Physics-Hybrid AI.

Ren Ozeki , Hamada Rizk , Hirozumi Yamaguchi

The 19th International Symposium on Spatial and Temporal Data. Doctoral Symposium. 2025.

DOI: 10.1145/3748777.3748805

Abstract

Due to global climate change, developing robust and accurate disaster prediction systems has become essential worldwide, as severe disasters are increasingly occurring even in previously safe regions.Two key technical challenges in disaster prediction are data scarcity and regional heterogeneity.Disasters are rare and extreme, resulting in limited data, which hinders data-driven approaches like machine learning (ML).Moreover, hydro-meteorological disasters depend on region-specific factors such as rainfall patterns, soil, vegetation, and infrastructure.These, combined with dynamic environmental changes from earthquakes, climate, and urbanization, complicate the generalization of models across time and space.We propose a self-adaptive physics-hybrid disaster prediction system that autonomously adapts to diverse and evolving environments to address this.Our system consists of: (1) a physics-hybrid disaster prediction model integrating physics-based hydro-meteorological simulation and multi-modal ML models, and (2) an environmental adaptation utilizing test-time adaptation (TTA) to update parameters without labeled disaster data(i.e., disaster event data).Our physics-hybrid model is anchored in the physics model to balance stability and adaptability, leveraging strengths from both physics and ML models.Furthermore, the strong inductive bias of the physics model mitigates overfitting and catastrophic forgetting during TTA, enabling robust adaptation to unseen regions.
A Simulation-based Framework for Dynamic Light Pollution Prediction in Urban Air Mobility

Ying Chieh Wang, Tatsuya Amano, Hirozumi Yamaguchi

2026 IEEE International Conference on Smart Computing (SmartComp), Messina, Italy, 2026, pp. 136-143

DOI 10.1109/SmartComp69968.2026.00029

Urban Air Mobility空飛ぶ車 +2

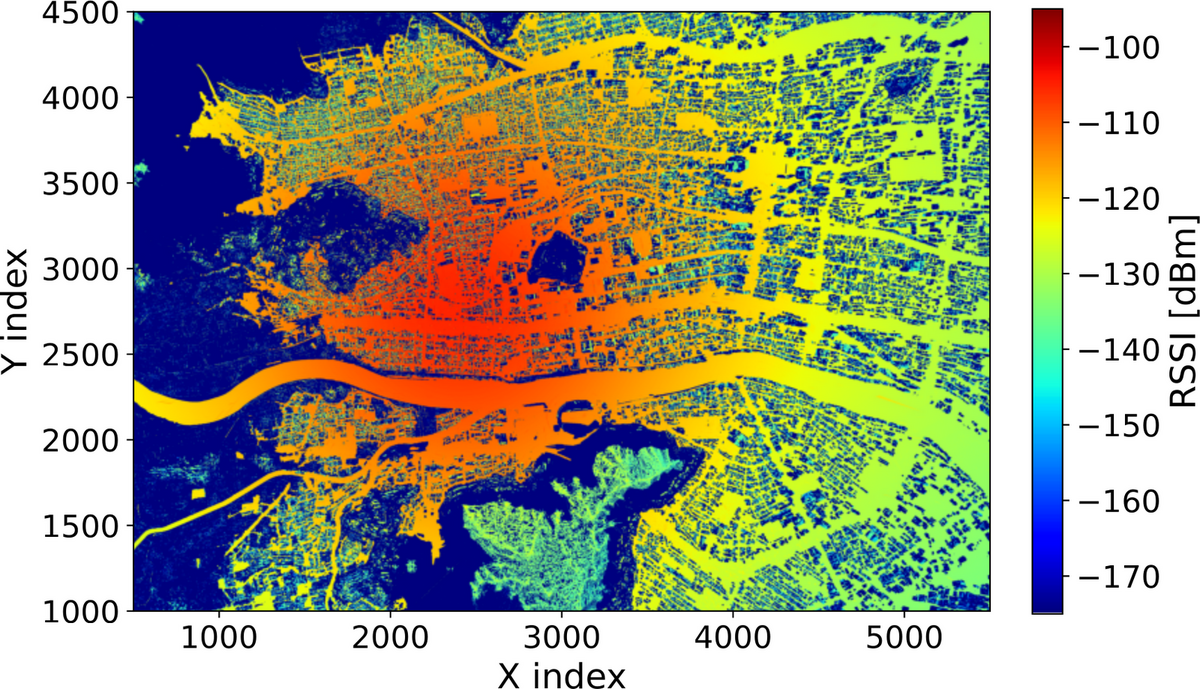
災害時LoRaネットワークのための環境認識型分散スケジューリング

Yuto Inaba, Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), SPT-IoT 2026, pp. 1366–1371

DOI 10.1109/PerComWorkshops68308.2026.11585469

災害通信LoRa +4

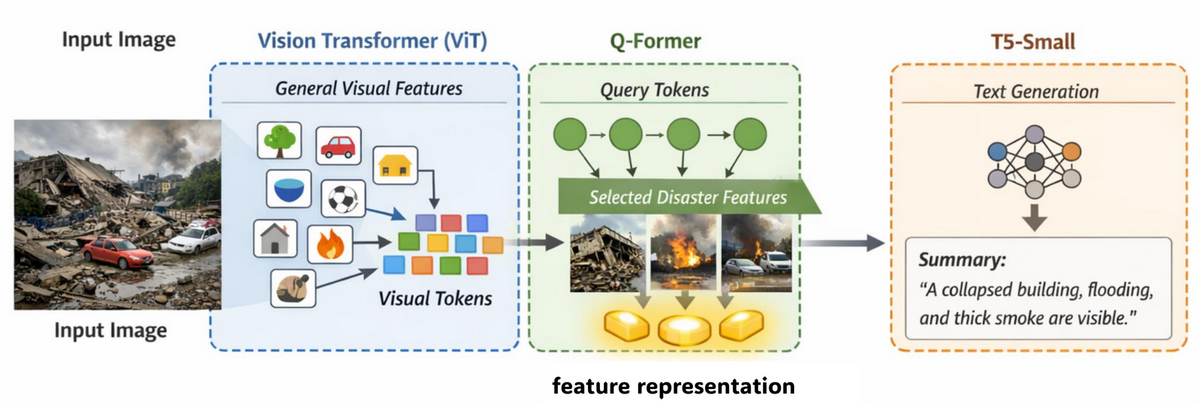
災害現場画像要約のための軽量Vision-Language Model

Hibiki Yoshizaki, Akira Uchiyama, Akihito Hiromori, Mineo Takai, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerconAI 2026, pp. 1203–1208

DOI 10.1109/PerComWorkshops68308.2026.11585419

セマンティック通信災害対応 +4

物理モデル統合型深層学習による都市の土砂災害予測

Ren Ozeki, Hamada Rizk, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), URBSENSE 2026, pp. 1094–1099

DOI 10.1109/PerComWorkshops68308.2026.11585337

土砂災害予測物理モデル統合学習 +3

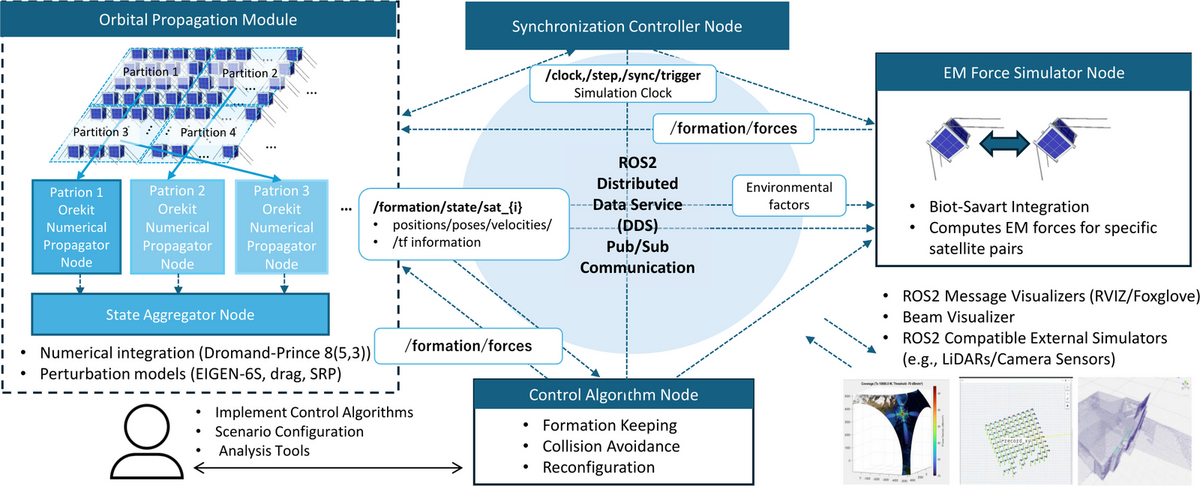
超大規模衛星群の精密編隊飛行に向けたシミュレーションフレームワーク

Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi, Sumio Morioka

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerVehicle , pp. 230–235

DOI 10.1109/PerComWorkshops68308.2026.11585321

衛星編隊飛行分散シミュレーション +4

レイトレーシング駆動型ISACレーダによるパターンベース車両認識

Heetae Jin, Akira Uchiyama

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerRad 2026, pp. 328–333

DOI 10.1109/PerComWorkshops68308.2026.11585327

ISACBeyond 5G +4