Balancing Privacy and Planning: Using Counterfactuals to Predict and Optimize Tourism in Wakayama City

International Conference · 2024

Balancing Privacy and Planning: Using Counterfactuals to Predict and Optimize Tourism in Wakayama City

Keywords

Visitor Mobility PatternsWakayama Castle ParkReconstruction of Mobility TrajectoriesStatistical AnalysisCounterfactual AnalysisAccessibility ConstraintsEnvironmental ConditionsDecision-Making ProcessesDesign of Mobility Services

Malvika Mishra , Srikant Manas Kala , Tatsuya Amano , Hirozumi Yamaguchi

In Proceedings of the 2nd ACM SIGSPATIAL International Workshop on Geo-Privacy and Data Utility for Smart Societies (GeoPrivacy '24), pp.25--30

DOI: 10.1145/3681768.3698504

Abstract

Leveraging predictive machine learning models on geo-spatial GPS data to analyze and predict tourist visits to Wakayama Castle, this study offers insights for urban design and policy-making. Employing counterfactual analysis, a novel approach in the tourism planning field, helps uncover key factors influencing visitation patterns and provide strategic recommendations for enhancing tourism. The comprehensive and targeted dataset of anonymized data, encompassing month long movement data, is used to train classification and regression models, which are compared and the best performing ones (Random Forest and CatBoost) are used in the counterfactual analysis. The counterfactual analysis demonstrates how changes in key factors, such as trip distance and start location, can significantly influence visitation decisions, allowing for targeted interventions to increase tourist activity. This research not only advances tourism management strategies but also prioritizes data privacy and user anonymity.

Research Note

Understanding visitor mobility in public spaces is essential for optimizing transportation services and improving accessibility. This study investigates mobility patterns within Wakayama Castle Park using questionnaire-based data. Participants reported both their thought destination (the locations they initially planned to visit using mobility vehicles) and their actual destination (the locations they ultimately reached using mobility vehicles). By reconstructing individual mobility trajectories from these responses, we quantify the difference in distance between intended and actual travel routes. Through statistical and counterfactual analyses, we identify key factors influencing deviations in mobility behavior, such as accessibility constraints, environmental conditions, and decision-making processes. The findings offer insights into user navigation challenges and inform the design of more effective mobility services for historical and recreational sites.


Published paper
  • Mishra, M., Kala, S. M., Amano, T., & Yamaguchi, H. (2024, October). Balancing Privacy and Planning: Using Counterfactuals to Predict and Optimize Tourism in Wakayama City. In Proceedings of the 2nd ACM SIGSPATIAL International Workshop on Geo-Privacy and Data Utility for Smart Societies (pp. 25-30). https://dl.acm.org/doi/abs/10.1145/3681768.3698504


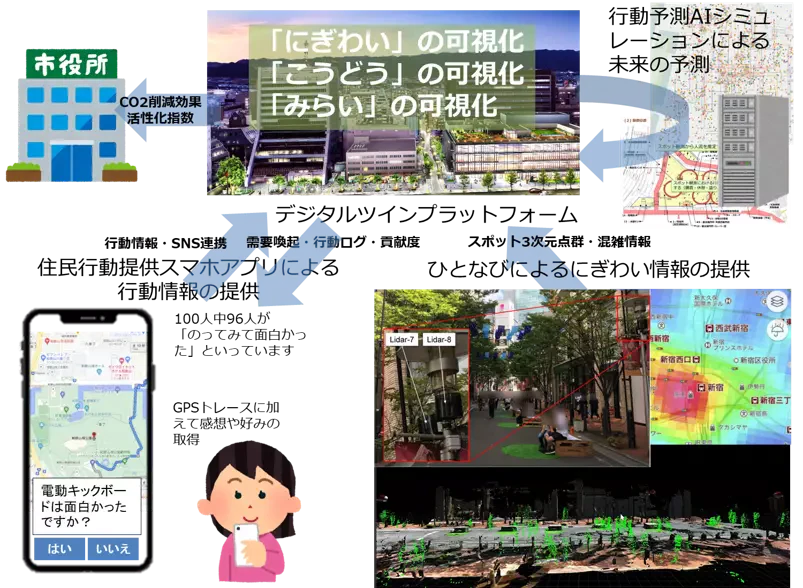
Triplet Co-Creation Digital Twin for Visualizing the Future of Cities

Triplet Co-Creation Digital Twin for Visualizing the Future of Cities

National Institute of Information and Communications Technology (NICT) 高度通信・放送研究開発委託研究
データ利活用等のデジタル化の推進による社会課題・地域課題解決のための実証型研究開発

A Simulation-based Framework for Dynamic Light Pollution Prediction in Urban Air Mobility

Ying Chieh Wang, Tatsuya Amano, Hirozumi Yamaguchi

2026 IEEE International Conference on Smart Computing (SmartComp), Messina, Italy, 2026, pp. 136-143

DOI 10.1109/SmartComp69968.2026.00029

Urban Air MobilityUAM +2

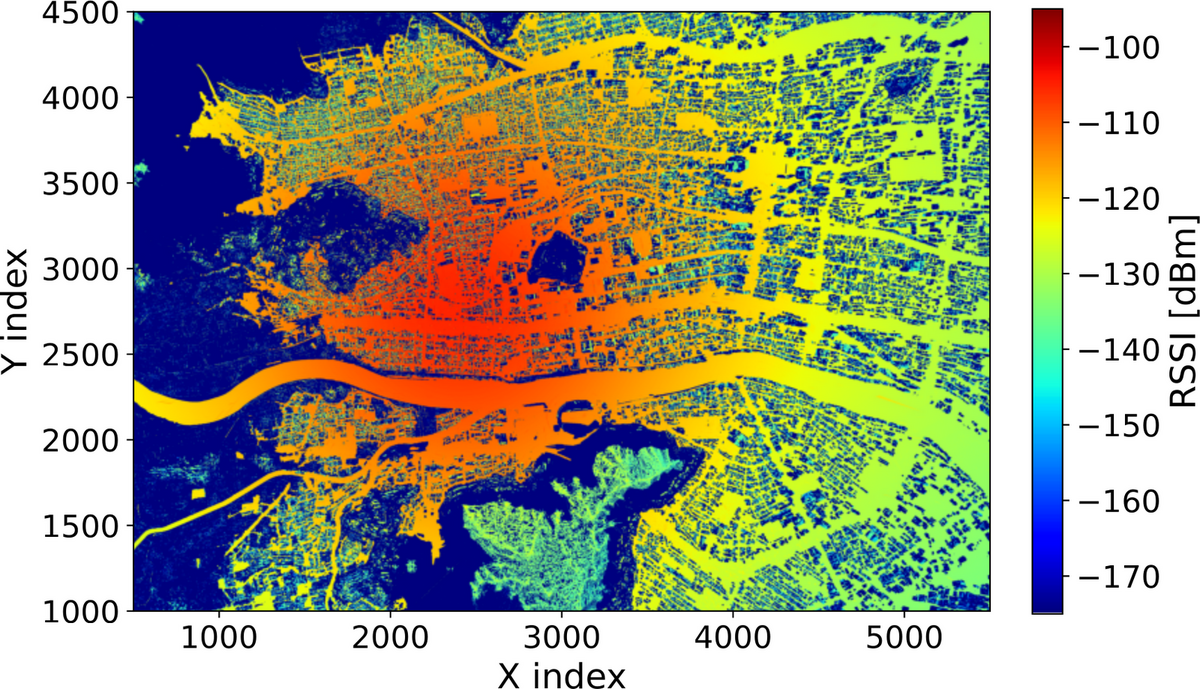
Environment-Aware Distributed Scheduling for Emergency LoRa Networks

Yuto Inaba, Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), SPT-IoT 2026, pp. 1366–1371

DOI 10.1109/PerComWorkshops68308.2026.11585469

Disaster CommunicationLoRa +4

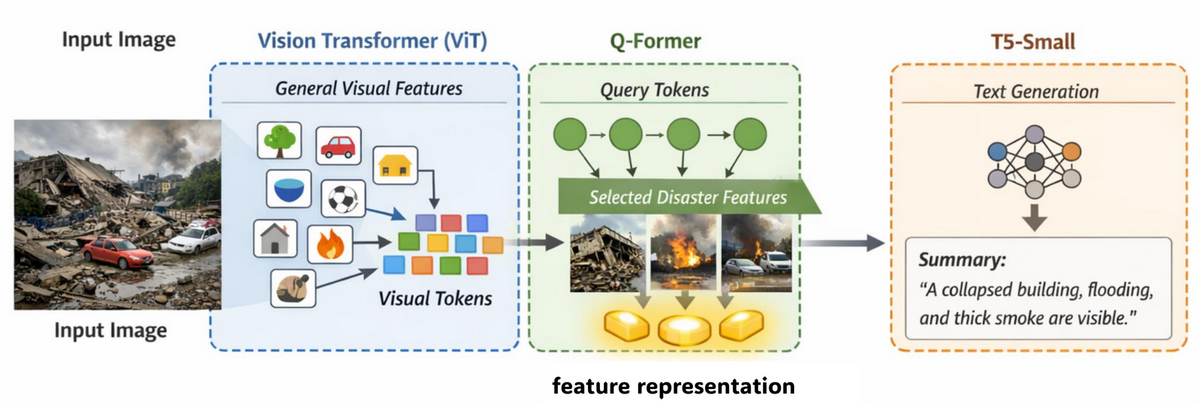
A Lightweight Vision-Language Model for Disaster Image Summarization

Hibiki Yoshizaki, Akira Uchiyama, Akihito Hiromori, Mineo Takai, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerconAI 2026, pp. 1203–1208

DOI 10.1109/PerComWorkshops68308.2026.11585419

Semantic CommunicationDisaster Response +4

Physics-Integrated Deep Learning for Urban Landslide Prediction

Ren Ozeki, Hamada Rizk, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), URBSENSE 2026, pp. 1094–1099

DOI 10.1109/PerComWorkshops68308.2026.11585337

Landslide PredictionPhysics-Integrated Learning +3

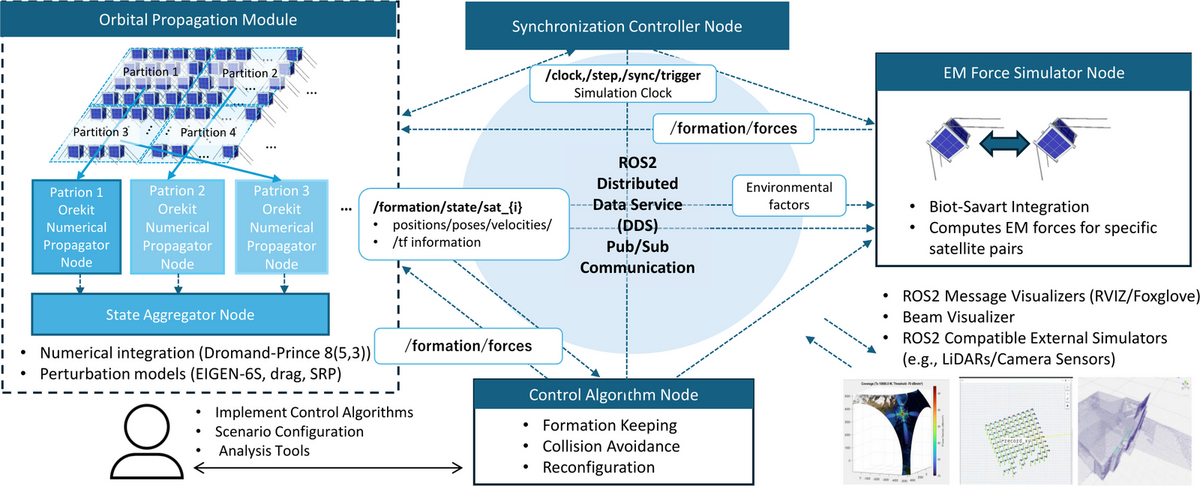
A Simulation Framework for Precision Formation Flying of Massive Satellite Swarms

Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi, Sumio Morioka

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerVehicle , pp. 230–235

DOI 10.1109/PerComWorkshops68308.2026.11585321

Satellite Formation FlyingDistributed Simulation +4

Ray-Tracing-Driven Pattern-Based Vehicle Recognition in ISAC Radar

Heetae Jin, Akira Uchiyama

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerRad 2026, pp. 328–333

DOI 10.1109/PerComWorkshops68308.2026.11585327

ISACBeyond 5G +4