Victim Detection Based on Shape Features from 3D Point Clouds

三次元点群からの形状特徴に基づく被災者判定

Victim Detection Based on Shape Features from 3D Point Clouds

Keywords

DroneLiDARVictim Detection

Japan experiences frequent natural disasters, including large-scale earthquakes. As seen in the case of the Great Hanshin-Awaji Earthquake, delayed victim discovery significantly reduces survival rates, emphasizing the need for rapid search and rescue operations. Drones offer flexible search capabilities, and recent advancements have focused on developing drone-assisted victim rescue systems. This study aims to achieve autonomous victim detection by integrating 3D LiDAR-equipped drones with machine learning, ensuring efficient searches unaffected by time of day or environmental conditions.

A Simulation-based Framework for Dynamic Light Pollution Prediction in Urban Air Mobility

Ying Chieh Wang, Tatsuya Amano, Hirozumi Yamaguchi

2026 IEEE International Conference on Smart Computing (SmartComp), Messina, Italy, 2026, pp. 136-143

DOI 10.1109/SmartComp69968.2026.00029

Urban Air MobilityUAM +2

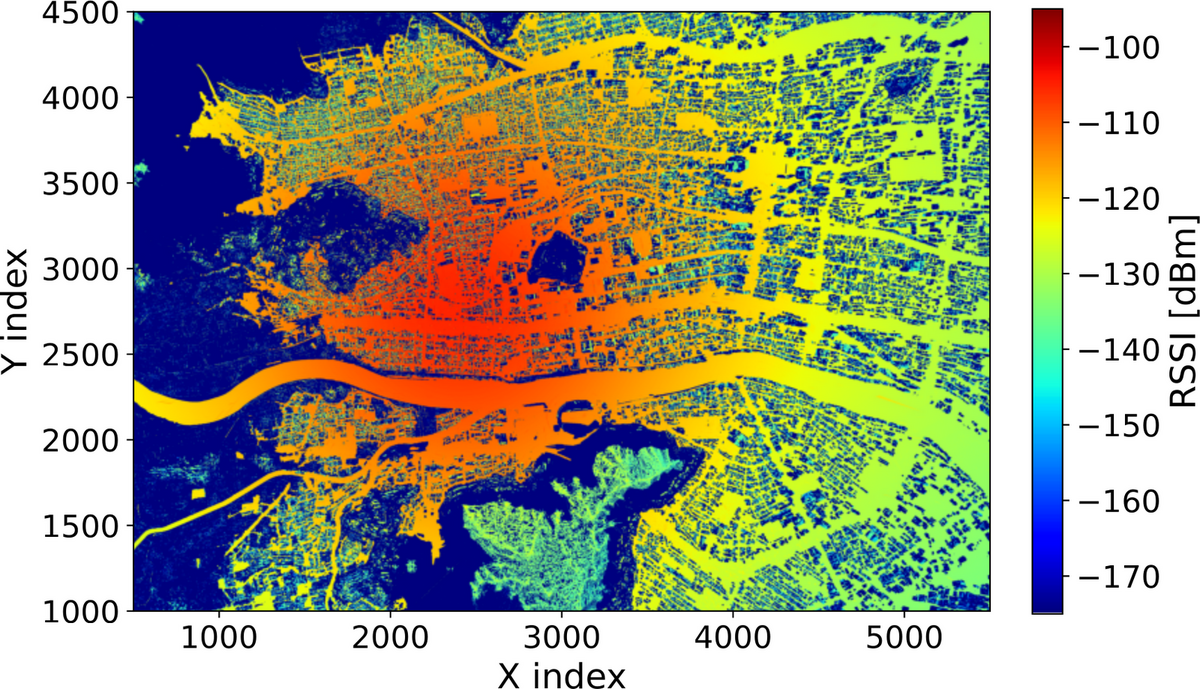
Environment-Aware Distributed Scheduling for Emergency LoRa Networks

Yuto Inaba, Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), SPT-IoT 2026, pp. 1366–1371

DOI 10.1109/PerComWorkshops68308.2026.11585469

Disaster CommunicationLoRa +4

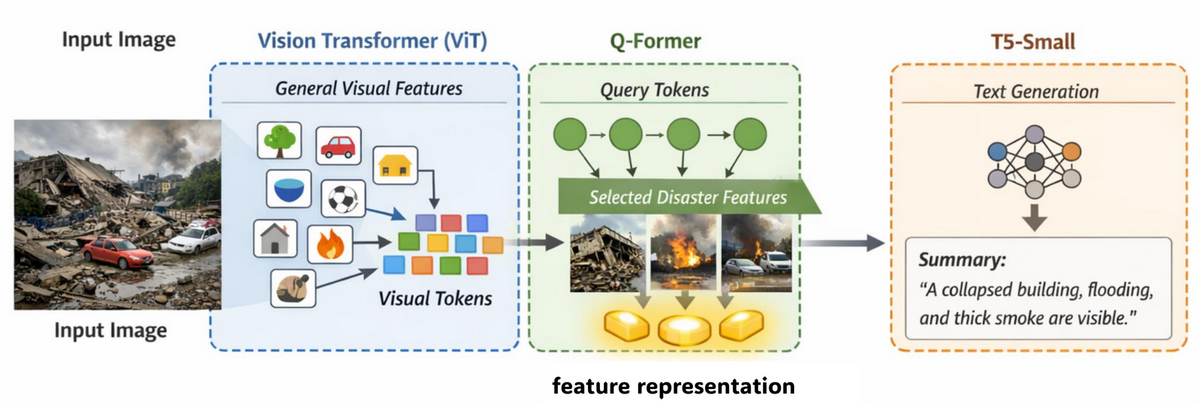
A Lightweight Vision-Language Model for Disaster Image Summarization

Hibiki Yoshizaki, Akira Uchiyama, Akihito Hiromori, Mineo Takai, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerconAI 2026, pp. 1203–1208

DOI 10.1109/PerComWorkshops68308.2026.11585419

Semantic CommunicationDisaster Response +4

Physics-Integrated Deep Learning for Urban Landslide Prediction

Ren Ozeki, Hamada Rizk, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), URBSENSE 2026, pp. 1094–1099

DOI 10.1109/PerComWorkshops68308.2026.11585337

Landslide PredictionPhysics-Integrated Learning +3

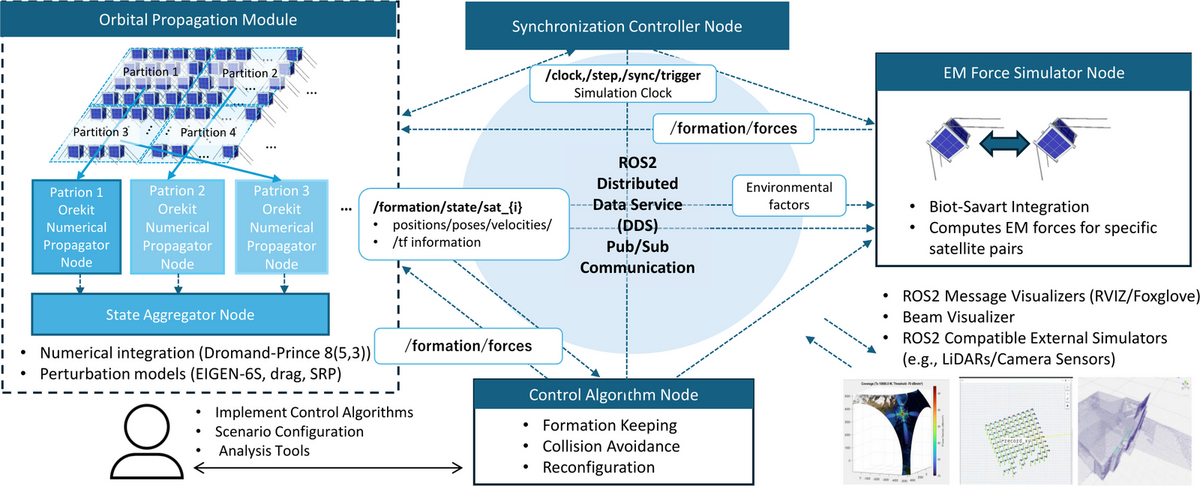
A Simulation Framework for Precision Formation Flying of Massive Satellite Swarms

Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi, Sumio Morioka

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerVehicle , pp. 230–235

DOI 10.1109/PerComWorkshops68308.2026.11585321

Satellite Formation FlyingDistributed Simulation +4

Ray-Tracing-Driven Pattern-Based Vehicle Recognition in ISAC Radar

Heetae Jin, Akira Uchiyama

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerRad 2026, pp. 328–333

DOI 10.1109/PerComWorkshops68308.2026.11585327

ISACBeyond 5G +4