Journal · 2024

Privacy-preserving pedestrian tracking with path image inpainting and 3D point cloud features

Masakazu Ohno , Riki Ukyo , Tatsuya Amano , Hamada Rizk , Hirozumi Yamaguchi

Pervasive and Mobile Computing, Volume 100, May 2024. 101914

DOI: 10.1016/j.pmcj.2024.101914

Abstract

Tracking pedestrian flow in large public areas is vital, yet ensuring privacy is paramount. Traditional visual-based tracking systems are raising concerns for potentially obtaining persistent and permanent identifiers that can compromise individual identities. Moreover, in areas such as the vicinity of restrooms, any form of data acquisition capturing human behavior should be refrained from, making it also crucial to appropriately address and complement these blind spots for a comprehensive analysis of pedestrian movement in the entire area. In this paper, we present our pedestrian tracking algorithm using distributed 3D LiDARs (Light Detection and Ranging), which capture pedestrians as 3D point clouds, omitting identifiable features. Our system bridges blind spots by leveraging historical movement data and 3D point cloud features, complemented by a generative diffusion model to predict trajectories in unseen areas. In a large-scale testbed with 70 LiDARs, the system achieved a 0.98 F-measure, highlighting its potential as a leading privacy-preserving tracking solution.

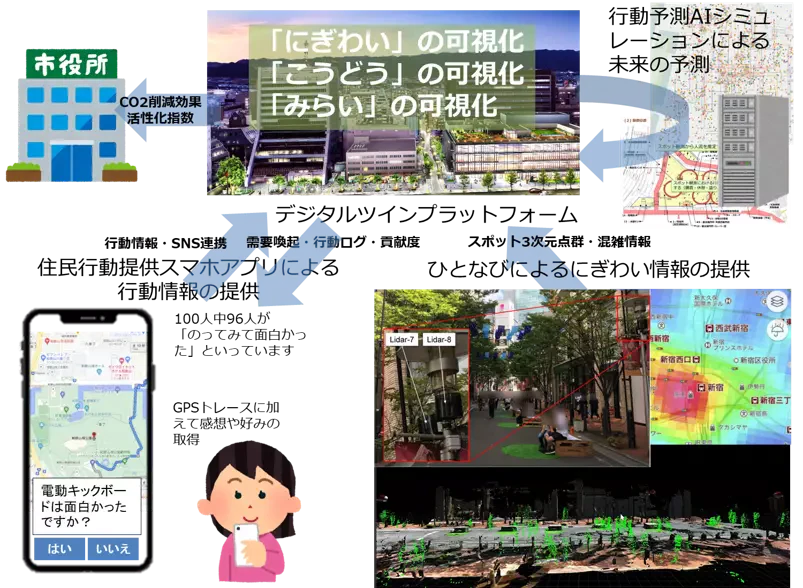
Triplet Co-Creation Digital Twin for Visualizing the Future of Cities

Triplet Co-Creation Digital Twin for Visualizing the Future of Cities

National Institute of Information and Communications Technology (NICT) 高度通信・放送研究開発委託研究
データ利活用等のデジタル化の推進による社会課題・地域課題解決のための実証型研究開発

A Simulation-based Framework for Dynamic Light Pollution Prediction in Urban Air Mobility

Ying Chieh Wang, Tatsuya Amano, Hirozumi Yamaguchi

2026 IEEE International Conference on Smart Computing (SmartComp), Messina, Italy, 2026, pp. 136-143

DOI 10.1109/SmartComp69968.2026.00029

Urban Air MobilityUAM +2

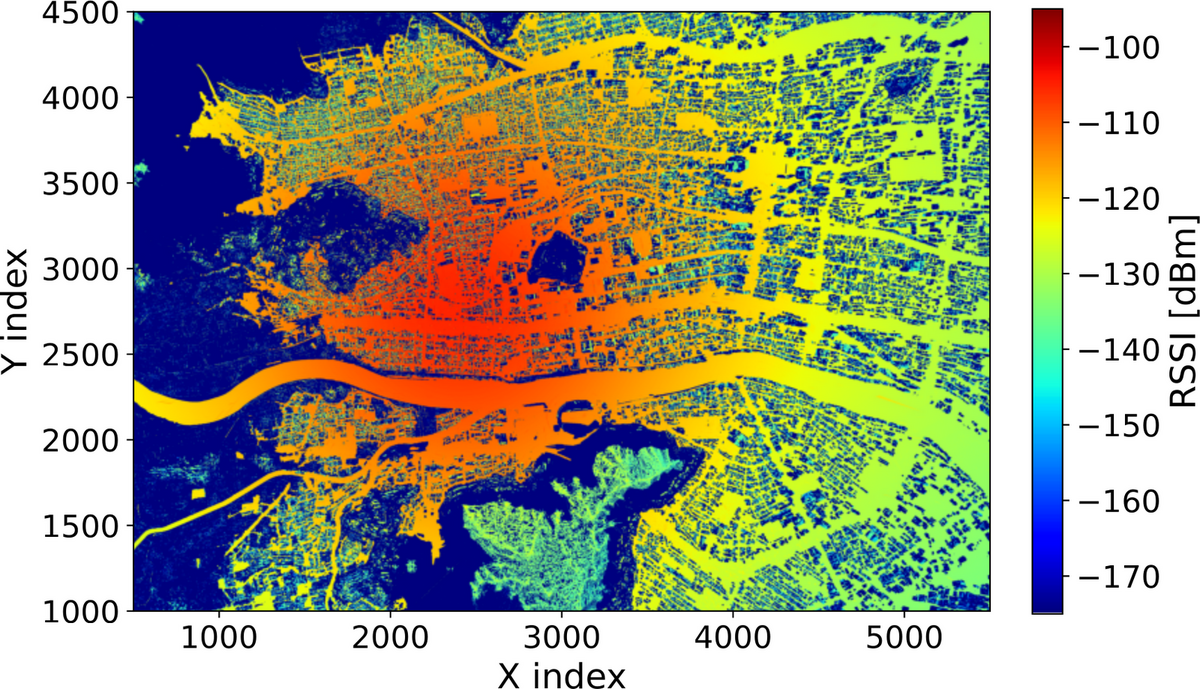
Environment-Aware Distributed Scheduling for Emergency LoRa Networks

Yuto Inaba, Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), SPT-IoT 2026, pp. 1366–1371

DOI 10.1109/PerComWorkshops68308.2026.11585469

Disaster CommunicationLoRa +4

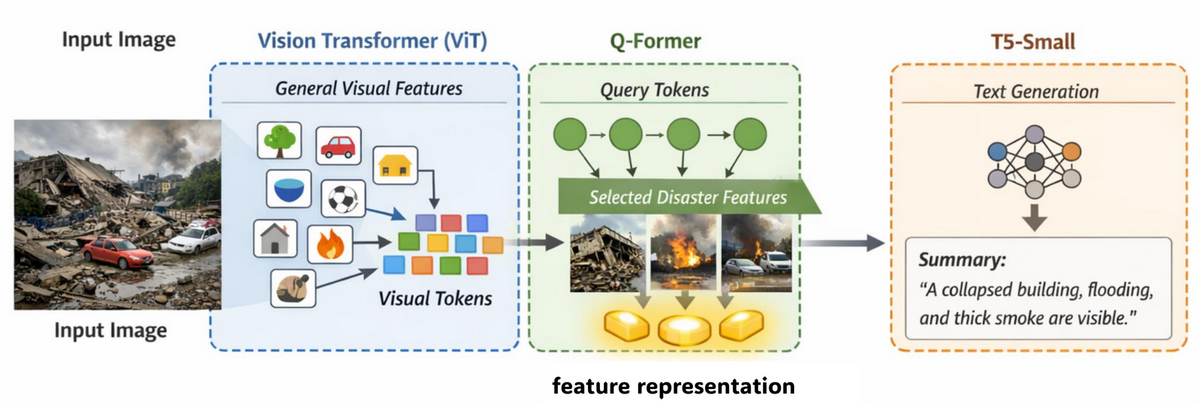
A Lightweight Vision-Language Model for Disaster Image Summarization

Hibiki Yoshizaki, Akira Uchiyama, Akihito Hiromori, Mineo Takai, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerconAI 2026, pp. 1203–1208

DOI 10.1109/PerComWorkshops68308.2026.11585419

Semantic CommunicationDisaster Response +4

Physics-Integrated Deep Learning for Urban Landslide Prediction

Ren Ozeki, Hamada Rizk, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), URBSENSE 2026, pp. 1094–1099

DOI 10.1109/PerComWorkshops68308.2026.11585337

Landslide PredictionPhysics-Integrated Learning +3

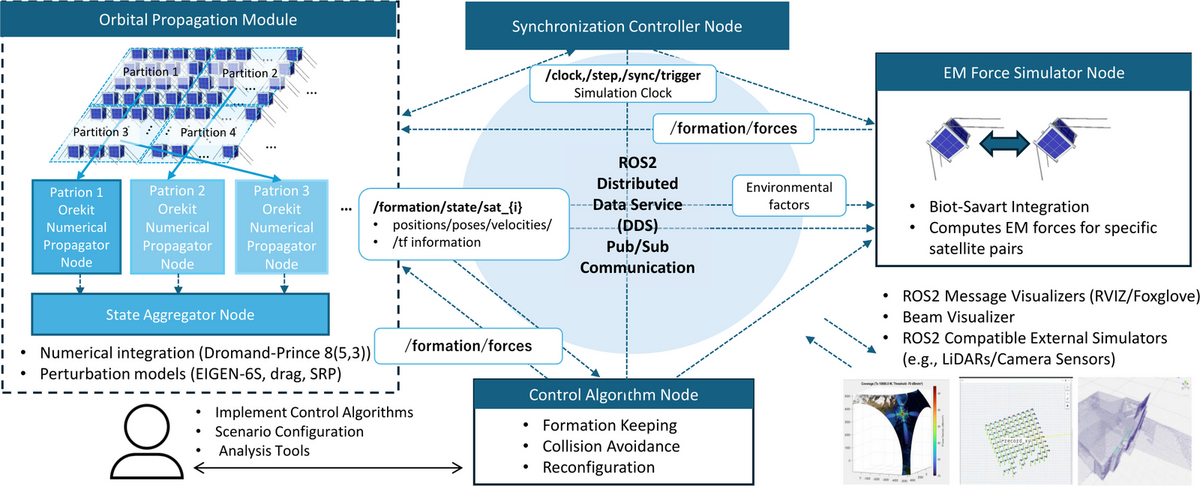
A Simulation Framework for Precision Formation Flying of Massive Satellite Swarms

Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi, Sumio Morioka

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerVehicle , pp. 230–235

DOI 10.1109/PerComWorkshops68308.2026.11585321

Satellite Formation FlyingDistributed Simulation +4

Ray-Tracing-Driven Pattern-Based Vehicle Recognition in ISAC Radar

Heetae Jin, Akira Uchiyama

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerRad 2026, pp. 328–333

DOI 10.1109/PerComWorkshops68308.2026.11585327

ISACBeyond 5G +4