Robust Pedestrian Tracking With Severe Occlusions in Public Spaces Using 3D Point Clouds

Journal · 2025

Robust Pedestrian Tracking With Severe Occlusions in Public Spaces Using 3D Point Clouds

Keywords

LIDARDpeth-cameraPedestrian TrackingKalman-filter

Riki Ukyo , Tatsuya Amano , Hamada Rizk , Hirozumi Yamaguchi , Takao Moriya

IEEE Transactions on Intelligent Transportation Systems, vol. 26, no. 6, pp. 8411-8423

DOI: 10.1109/TITS.2025.3547418

Abstract

The increasing need for pedestrian tracking within public and commercial domains necessitates innovative solutions that respect privacy concerns. Traditional surveillance methods employing RGB video footage for the monitoring of pedestrian movements have raised significant privacy issues, attributed to their capability to easily identify individuals. This paper shifts focus towards the utilization of 3D point cloud data as a less intrusive alternative for pedestrian monitoring, which inherently minimizes the risk of individual identification. Notwithstanding, traditional tracking methodologies frequently encounter difficulties in environments characterized by high pedestrian density, where occlusions caused by individuals obscuring one another from the sensors’ perspective are commonplace. This research introduces an advanced approach leveraging 3D point cloud data to address the challenges inherent in pedestrian tracking. A particular obstacle addressed is the frequent obstruction caused by pedestrians, who may be accompanied by objects such as baby strollers and/or luggage, thus complicating their detection and tracking when positioned behind others or in close proximity to the sensors. Such scenarios significantly undermine the efficacy of pedestrian segmentation and tracking, particularly in the context of Kalman-Filter-based methodologies. To mitigate these challenges, the proposed solution incorporates a method to spatially enhance the missing segments within the framework of Kalman-Filter-based multi-object tracking. The effectiveness of this approach has been rigorously assessed through the application of 3D point cloud data derived from diverse real-world settings, including laboratory environments, shopping mall entrances, and a densely populated urban area in Kita-ku, Osaka City, during a festival event.

Research Note

We propose an approach to pedestrian tracking in a public passageway with pedestrians, such as those carrying luggage and baby strollers, and family groups close to each other, based on 3D point cloud data captured by a single 3D depth sensor. Since we assume a wall-attached sensor, which is easy to deploy in passageways, pedestrians walking nearby the sensor frequently occlude the others behind. This causes a severe error in pedestrian segmentation in the 3D point cloud and Kalman-filter-based tracking. We introduce a new technique to spatially complement the missing part of segments in Kalman-filter-based multi-object tracking to cope with this issue. We have evaluated our method using the 3D point cloud data capturing pedestrians at the entrance of an existing commercial facility (shopping small) and the one collected in our laboratory space. As a result, the tracking accuracy index (MOTA) for multiple objects is 0.914, with severe and frequent occlusions.
Published Paper:

  • 右京莉規, 扇田幹己, 山田遊馬, 廣森聡仁, 山口弘純, & 東野輝夫. (2020). 三次元深度センサーを用いた移動制約者検出手法の提案と評価. マルチメディア, 分散協調とモバイルシンポジウム 2204 論文集, 2020, 1280-1289.
  • 右京莉規, 廣森聡仁, 山口弘純, & 東野輝夫. (2020). 公共空間における三次元点群の不完全性に対して堅牢な歩行者トラッキング手法. 研究報告マルチメディア通信と分散処理 (DPS), 2020(2), 1-8.
  • 右京莉規, 天野辰哉, 廣森聡仁, 山口弘純, & 東野輝夫. (2021). 多様な人物属性を考慮した堅牢なトラッキング手法の実装と評価. 研究報告モバイルコンピューティングと新社会システム (MBL), 2021(25), 1-8.
  • 右京莉規, 天野辰哉, 廣森聡仁, 山口弘純, & 守屋充雄. (2021). 複数 LiDAR による大規模三次元点群を用いた歩行者トラッキング手法の実装と評価. 研究報告モバイルコンピューティングと新社会システム (MBL), 2021(28), 1-7.
  • Riki Ukyo, Tatsuya Amano, Akihito Hiromori and Hirozumi Yamaguchi, "Pedestrian Tracking in Public Passageway by Single 3D Depth Sensor", Proceedings of the 2022 IEEE International Workshop on Pervasive Computing for Vehicular Systems Co-located with IEEE PerCom 2022, pp. 581-586
  • 右京莉規, 天野辰哉, 廣森聡仁, & 山口弘純. (2022). 3 次元点群を用いた高密度群衆の人数推定手法. マルチメディア, 分散, 協調とモバイルシンポジウム 2022 論文集, 2022, 852-858.
  • 右京 莉規, 天野 辰哉, 廣森 聡仁, 山口 弘純, 東野 輝夫, "公共空間における三次元点群の不完全性に対して堅牢な歩行者トラッキング手法", 情報処理学会論文誌, Vol.63, No.8, pp.1361-1370 (2022-08-15)
  • 右京莉規, 天野辰哉, & 山口弘純. (2023). 3 次元点群を用いた不規則に移動する高密度群衆下での歩行者トラッキング. マルチメディア, 分散, 協調とモバイルシンポジウム 2023 論文集, 2023, 986-995.
  • Ukyo, R., Amano, T., Rizk, H., & Yamaguchi, H. (2023, September). Pedestrian tracking using 3d lidars–case for proximity scenario. In 2023 IEEE 26th International Conference on Intelligent Transportation Systems (ITSC) (pp. 4683-4689). IEEE.


LLM-Driven Urban Transportation Simulation Platform

LLM-Driven Urban Transportation Simulation Platform

Japan Science and Technology Agency (JST) JST Strategic Basic Research Programs (PRESTO)
[Social Transformation Platform] Co-Creation of the Transformation Platform Technology for Human and Society by Integration of the Humanities and Sciences

A Simulation-based Framework for Dynamic Light Pollution Prediction in Urban Air Mobility

Ying Chieh Wang, Tatsuya Amano, Hirozumi Yamaguchi

2026 IEEE International Conference on Smart Computing (SmartComp), Messina, Italy, 2026, pp. 136-143

DOI 10.1109/SmartComp69968.2026.00029

Urban Air MobilityUAM +2

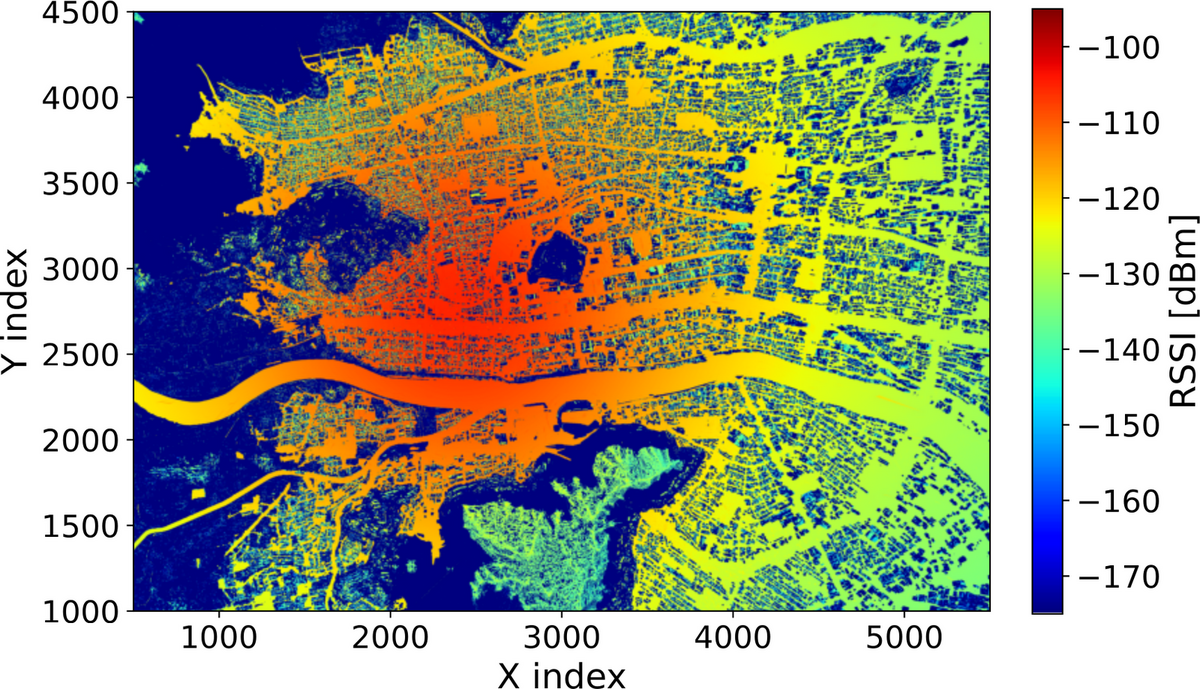
Environment-Aware Distributed Scheduling for Emergency LoRa Networks

Yuto Inaba, Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), SPT-IoT 2026, pp. 1366–1371

DOI 10.1109/PerComWorkshops68308.2026.11585469

Disaster CommunicationLoRa +4

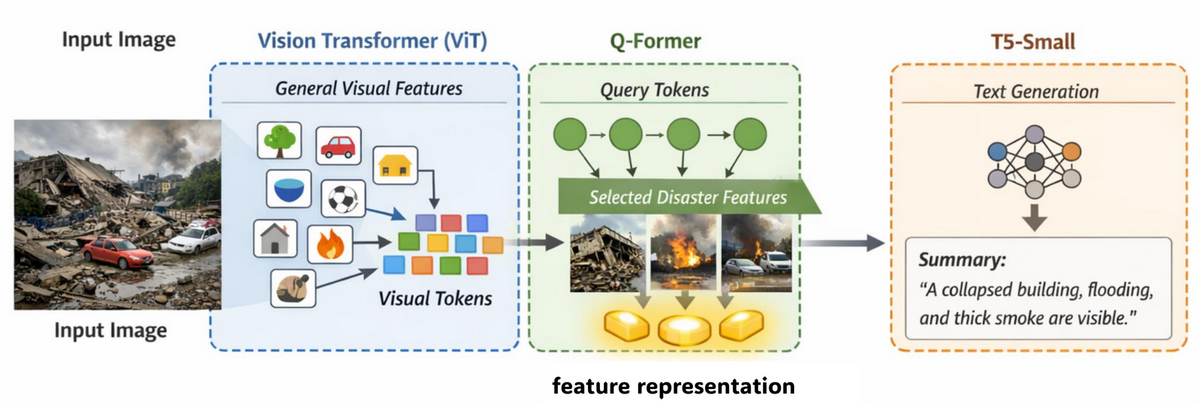
A Lightweight Vision-Language Model for Disaster Image Summarization

Hibiki Yoshizaki, Akira Uchiyama, Akihito Hiromori, Mineo Takai, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerconAI 2026, pp. 1203–1208

DOI 10.1109/PerComWorkshops68308.2026.11585419

Semantic CommunicationDisaster Response +4

Physics-Integrated Deep Learning for Urban Landslide Prediction

Ren Ozeki, Hamada Rizk, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), URBSENSE 2026, pp. 1094–1099

DOI 10.1109/PerComWorkshops68308.2026.11585337

Landslide PredictionPhysics-Integrated Learning +3

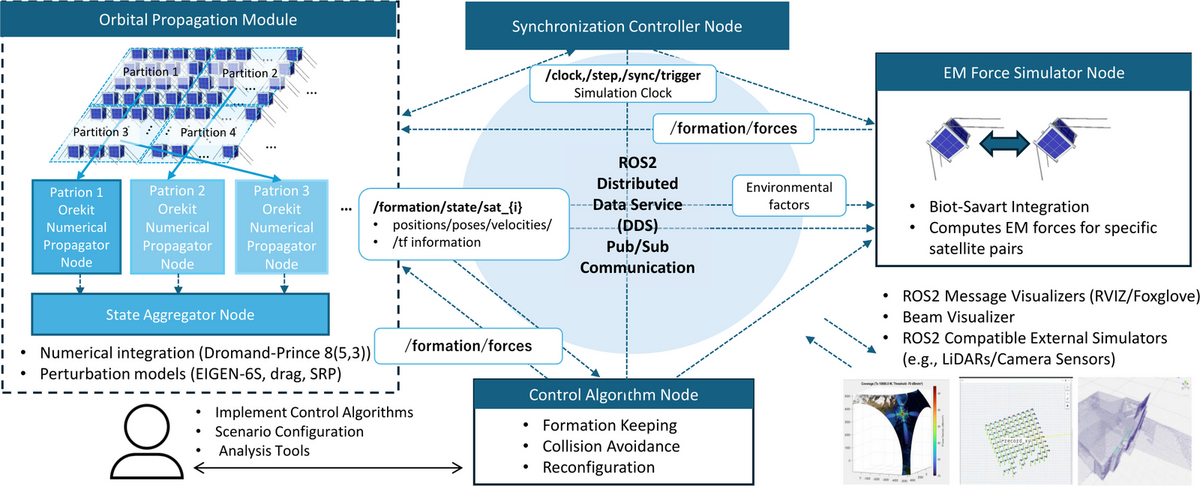
A Simulation Framework for Precision Formation Flying of Massive Satellite Swarms

Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi, Sumio Morioka

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerVehicle , pp. 230–235

DOI 10.1109/PerComWorkshops68308.2026.11585321

Satellite Formation FlyingDistributed Simulation +4

Ray-Tracing-Driven Pattern-Based Vehicle Recognition in ISAC Radar

Heetae Jin, Akira Uchiyama

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerRad 2026, pp. 328–333

DOI 10.1109/PerComWorkshops68308.2026.11585327

ISACBeyond 5G +4