Collaborative Lightweight LLM Agents for Daily Activity Summarization on Edge Devices

International Conference · 2025

Collaborative Lightweight LLM Agents for Daily Activity Summarization on Edge Devices

Keywords

LLMMonitoring

Kentaro Inohara , Tatsuya Amano , Hamada Rizk , Hirozumi Yamaguchi

Proceedings of the 21st International Conference on Intelligent Environments (IE 2025), Darmstadt, Germany, 2025, pp. 1-4

DOI: 10.1109/IE64880.2025.11130095

Abstract

This paper presents a privacy-preserving monitoring system for elderly individuals living alone, utilizing collaborative lightweight Large Language Model (LLM) agents deployed on edge devices. The system integrates non-invasive sensors with a novel three-agent architecture: an activity recognition agent processes sensor data, an hourly summarization agent generates intermediate reports in 3-hour segments, and a daily summarization agent produces comprehensive summaries. Our evaluation on real-world data from two elderly households demonstrates that the system achieves 95.8% accuracy in activity recognition and generates natural language summaries comparable to GPT-4o, while maintaining privacy through local processing on affordable Raspberry Pi hardware. The results indicate that our approach effectively balances monitoring accuracy, summary quality, and practical deployment constraints, making it suitable for widespread adoption in elderly care applications.

Research Note

In recent years, with the increase in the number of elderly people living alone, the demand for monitoring systems has increased. There are two main requirements for a monitoring system: first, it must protect privacy, and second, it must be low-cost and easy to implement. This study proposes a daily activity summarization system for privacy-preserving monitoring of elderly individuals living alone, utilizing collaborative lightweight Large Language Model (LLM) agents deployed on edge devices. The system integrates non-invasive sensors with a novel three-agent architecture: an activity recognition agent processes sensor data by machine learning approach, an hourly summarization LLM agent generates intermediate reports in 3-hour segments, and a daily summarization LLM agent produces comprehensive summaries. The proposed multi-agent approach for summary generation was designed not only to achieve load balancing but also to enhance the quality of the outputs. By distributing tasks among three agents based on time intervals and context-specific activities, the system effectively captured both short-term and long-term activity patterns, preserving critical temporal dependencies. This division reduced variability and inconsistencies by enabling each agent to focus on a manageable data segment, ensuring accurate and context-aware processing.

LLM-Driven Urban Transportation Simulation Platform

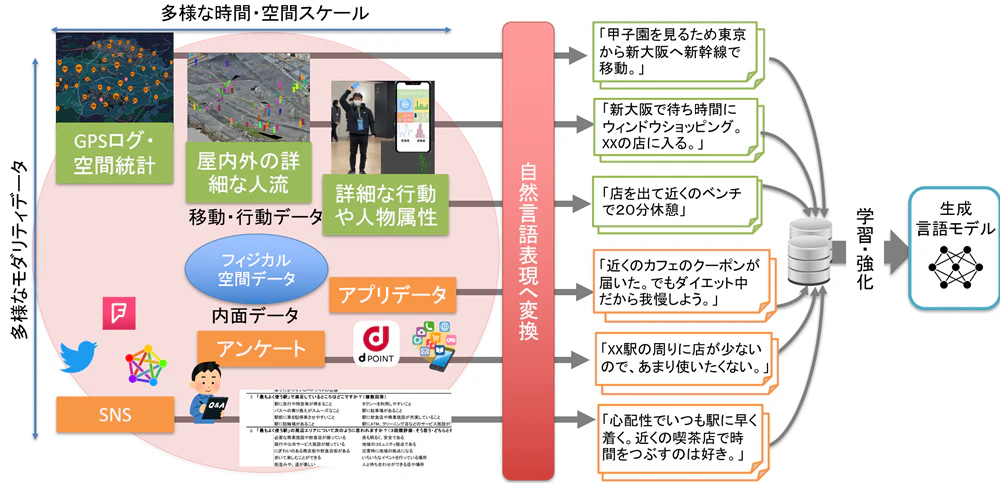
LLM-Driven Urban Transportation Simulation Platform

Japan Science and Technology Agency (JST) JST Strategic Basic Research Programs (PRESTO)
[Social Transformation Platform] Co-Creation of the Transformation Platform Technology for Human and Society by Integration of the Humanities and Sciences

A Simulation-based Framework for Dynamic Light Pollution Prediction in Urban Air Mobility

Ying Chieh Wang, Tatsuya Amano, Hirozumi Yamaguchi

2026 IEEE International Conference on Smart Computing (SmartComp), Messina, Italy, 2026, pp. 136-143

DOI 10.1109/SmartComp69968.2026.00029

Urban Air MobilityUAM +2

Environment-Aware Distributed Scheduling for Emergency LoRa Networks

Yuto Inaba, Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), SPT-IoT 2026, pp. 1366–1371

DOI 10.1109/PerComWorkshops68308.2026.11585469

Disaster CommunicationLoRa +4

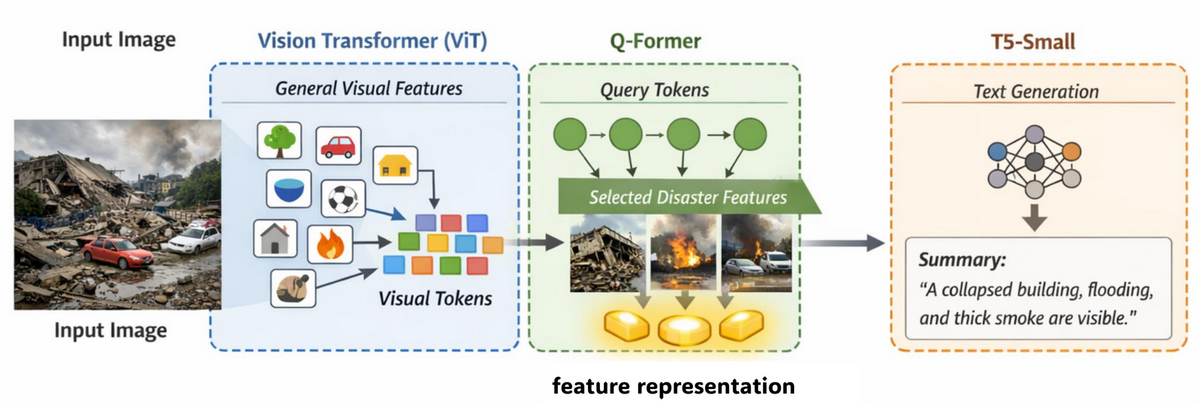
A Lightweight Vision-Language Model for Disaster Image Summarization

Hibiki Yoshizaki, Akira Uchiyama, Akihito Hiromori, Mineo Takai, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerconAI 2026, pp. 1203–1208

DOI 10.1109/PerComWorkshops68308.2026.11585419

Semantic CommunicationDisaster Response +4

Physics-Integrated Deep Learning for Urban Landslide Prediction

Ren Ozeki, Hamada Rizk, Hirozumi Yamaguchi

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), URBSENSE 2026, pp. 1094–1099

DOI 10.1109/PerComWorkshops68308.2026.11585337

Landslide PredictionPhysics-Integrated Learning +3

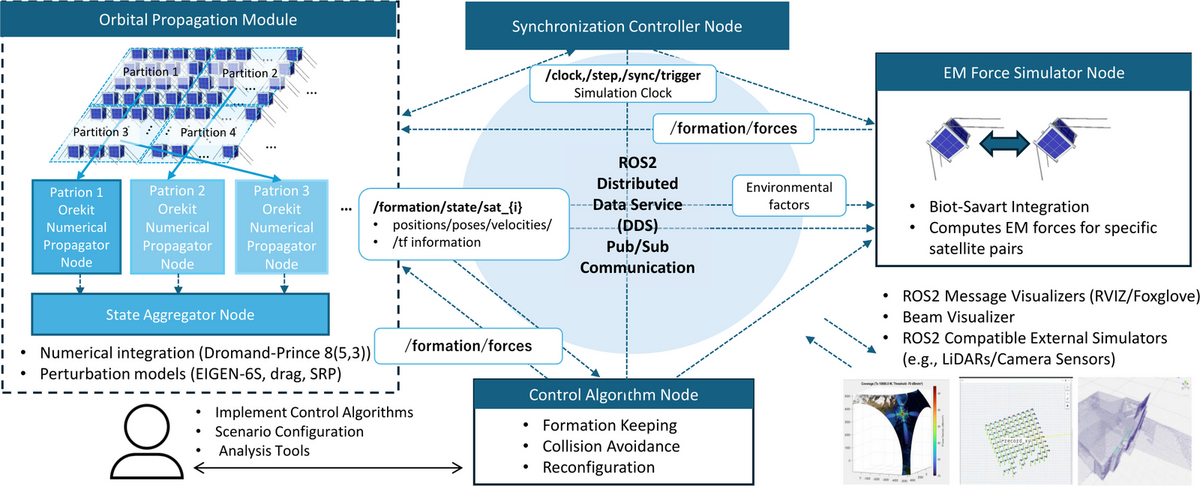
A Simulation Framework for Precision Formation Flying of Massive Satellite Swarms

Tatsuya Amano, Akihito Hiromori, Hirozumi Yamaguchi, Sumio Morioka

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerVehicle , pp. 230–235

DOI 10.1109/PerComWorkshops68308.2026.11585321

Satellite Formation FlyingDistributed Simulation +4

Ray-Tracing-Driven Pattern-Based Vehicle Recognition in ISAC Radar

Heetae Jin, Akira Uchiyama

2026 IEEE International Conference on Pervasive Computing and Communications Workshops and other Affiliated Events (PerCom Workshops), PerRad 2026, pp. 328–333

DOI 10.1109/PerComWorkshops68308.2026.11585327

ISACBeyond 5G +4